Company
About
Us
Careers
Products
Hands
Humanoids
Actuators
Services
Engineering Services
Contact Us
Dexterous Hands
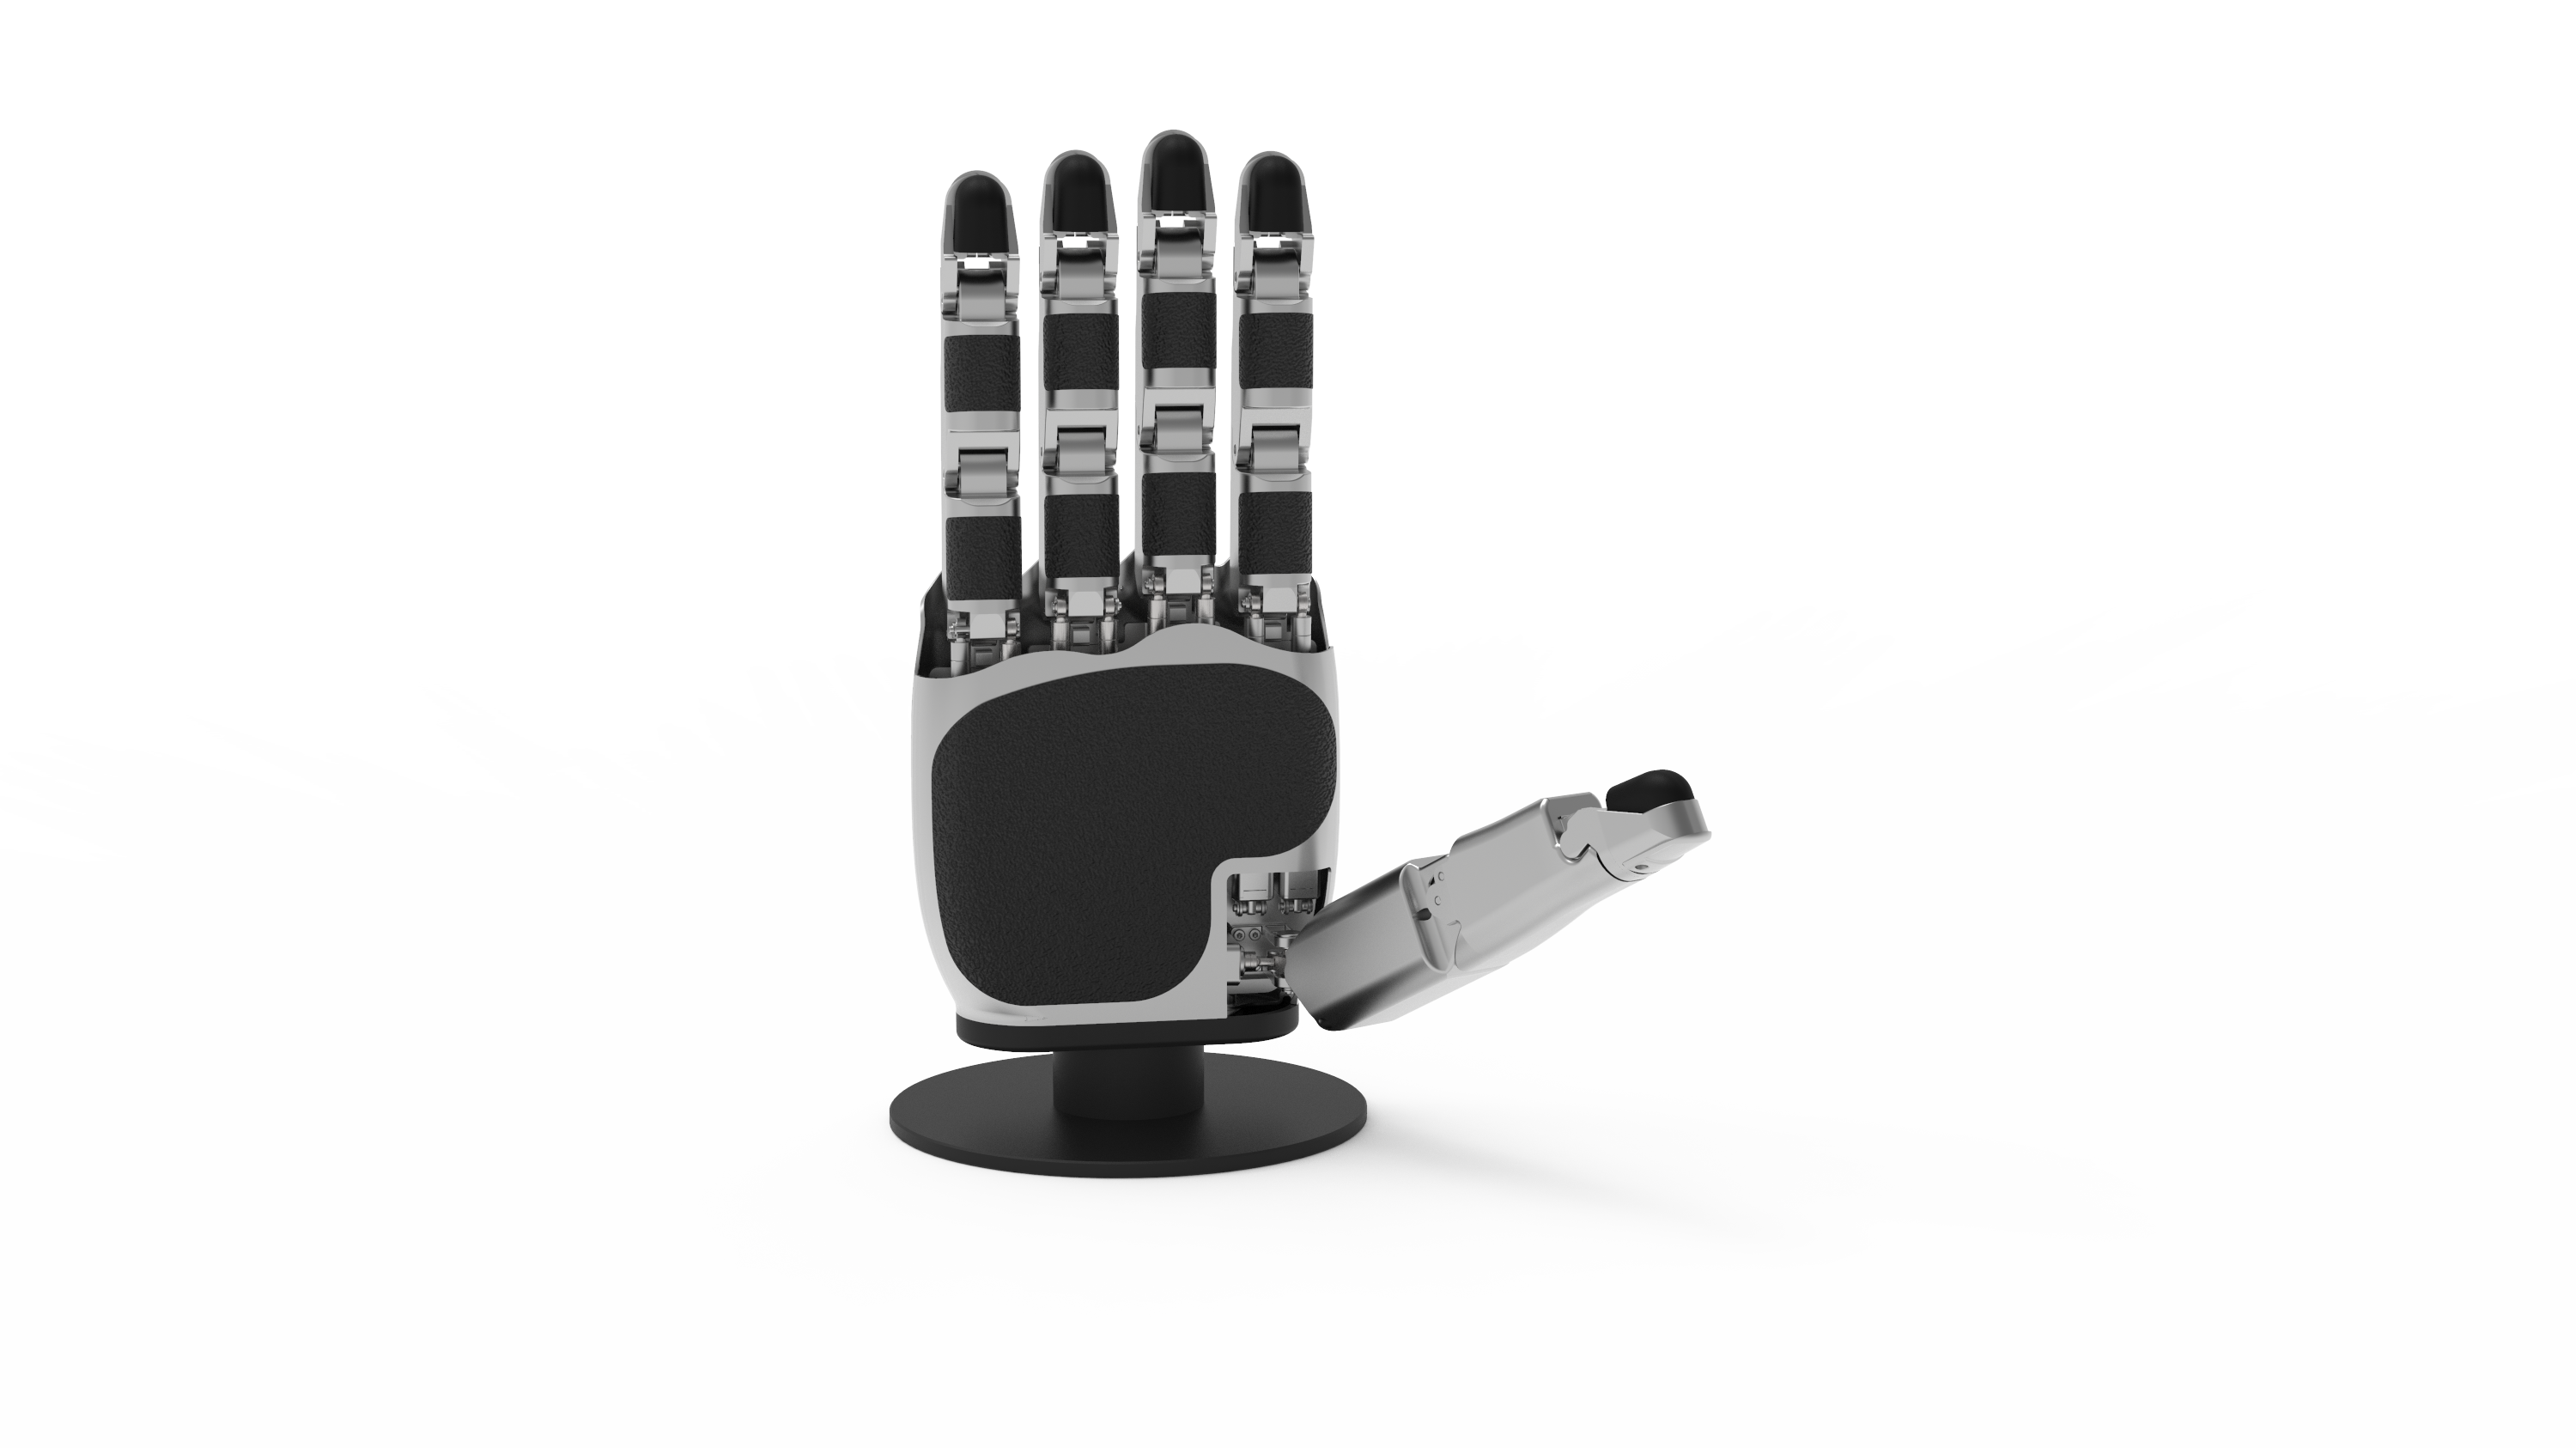
SF DEXA 01
SF DEXA 01 adopts a direct-drive architecture, bringing actuation closer to each finger joint and creating a compact, highly integrated robotic hand.
Degrees of Freedom:
20 Active
Dimension:
210 × 94 × 44 mm
Weight:
945 g
Drive Method:
Direct
Communication:
CAN / CAN FD / RS485 / ECAT
Flexion/Extension Speed:
0.47 s
Max Load:
32 kg
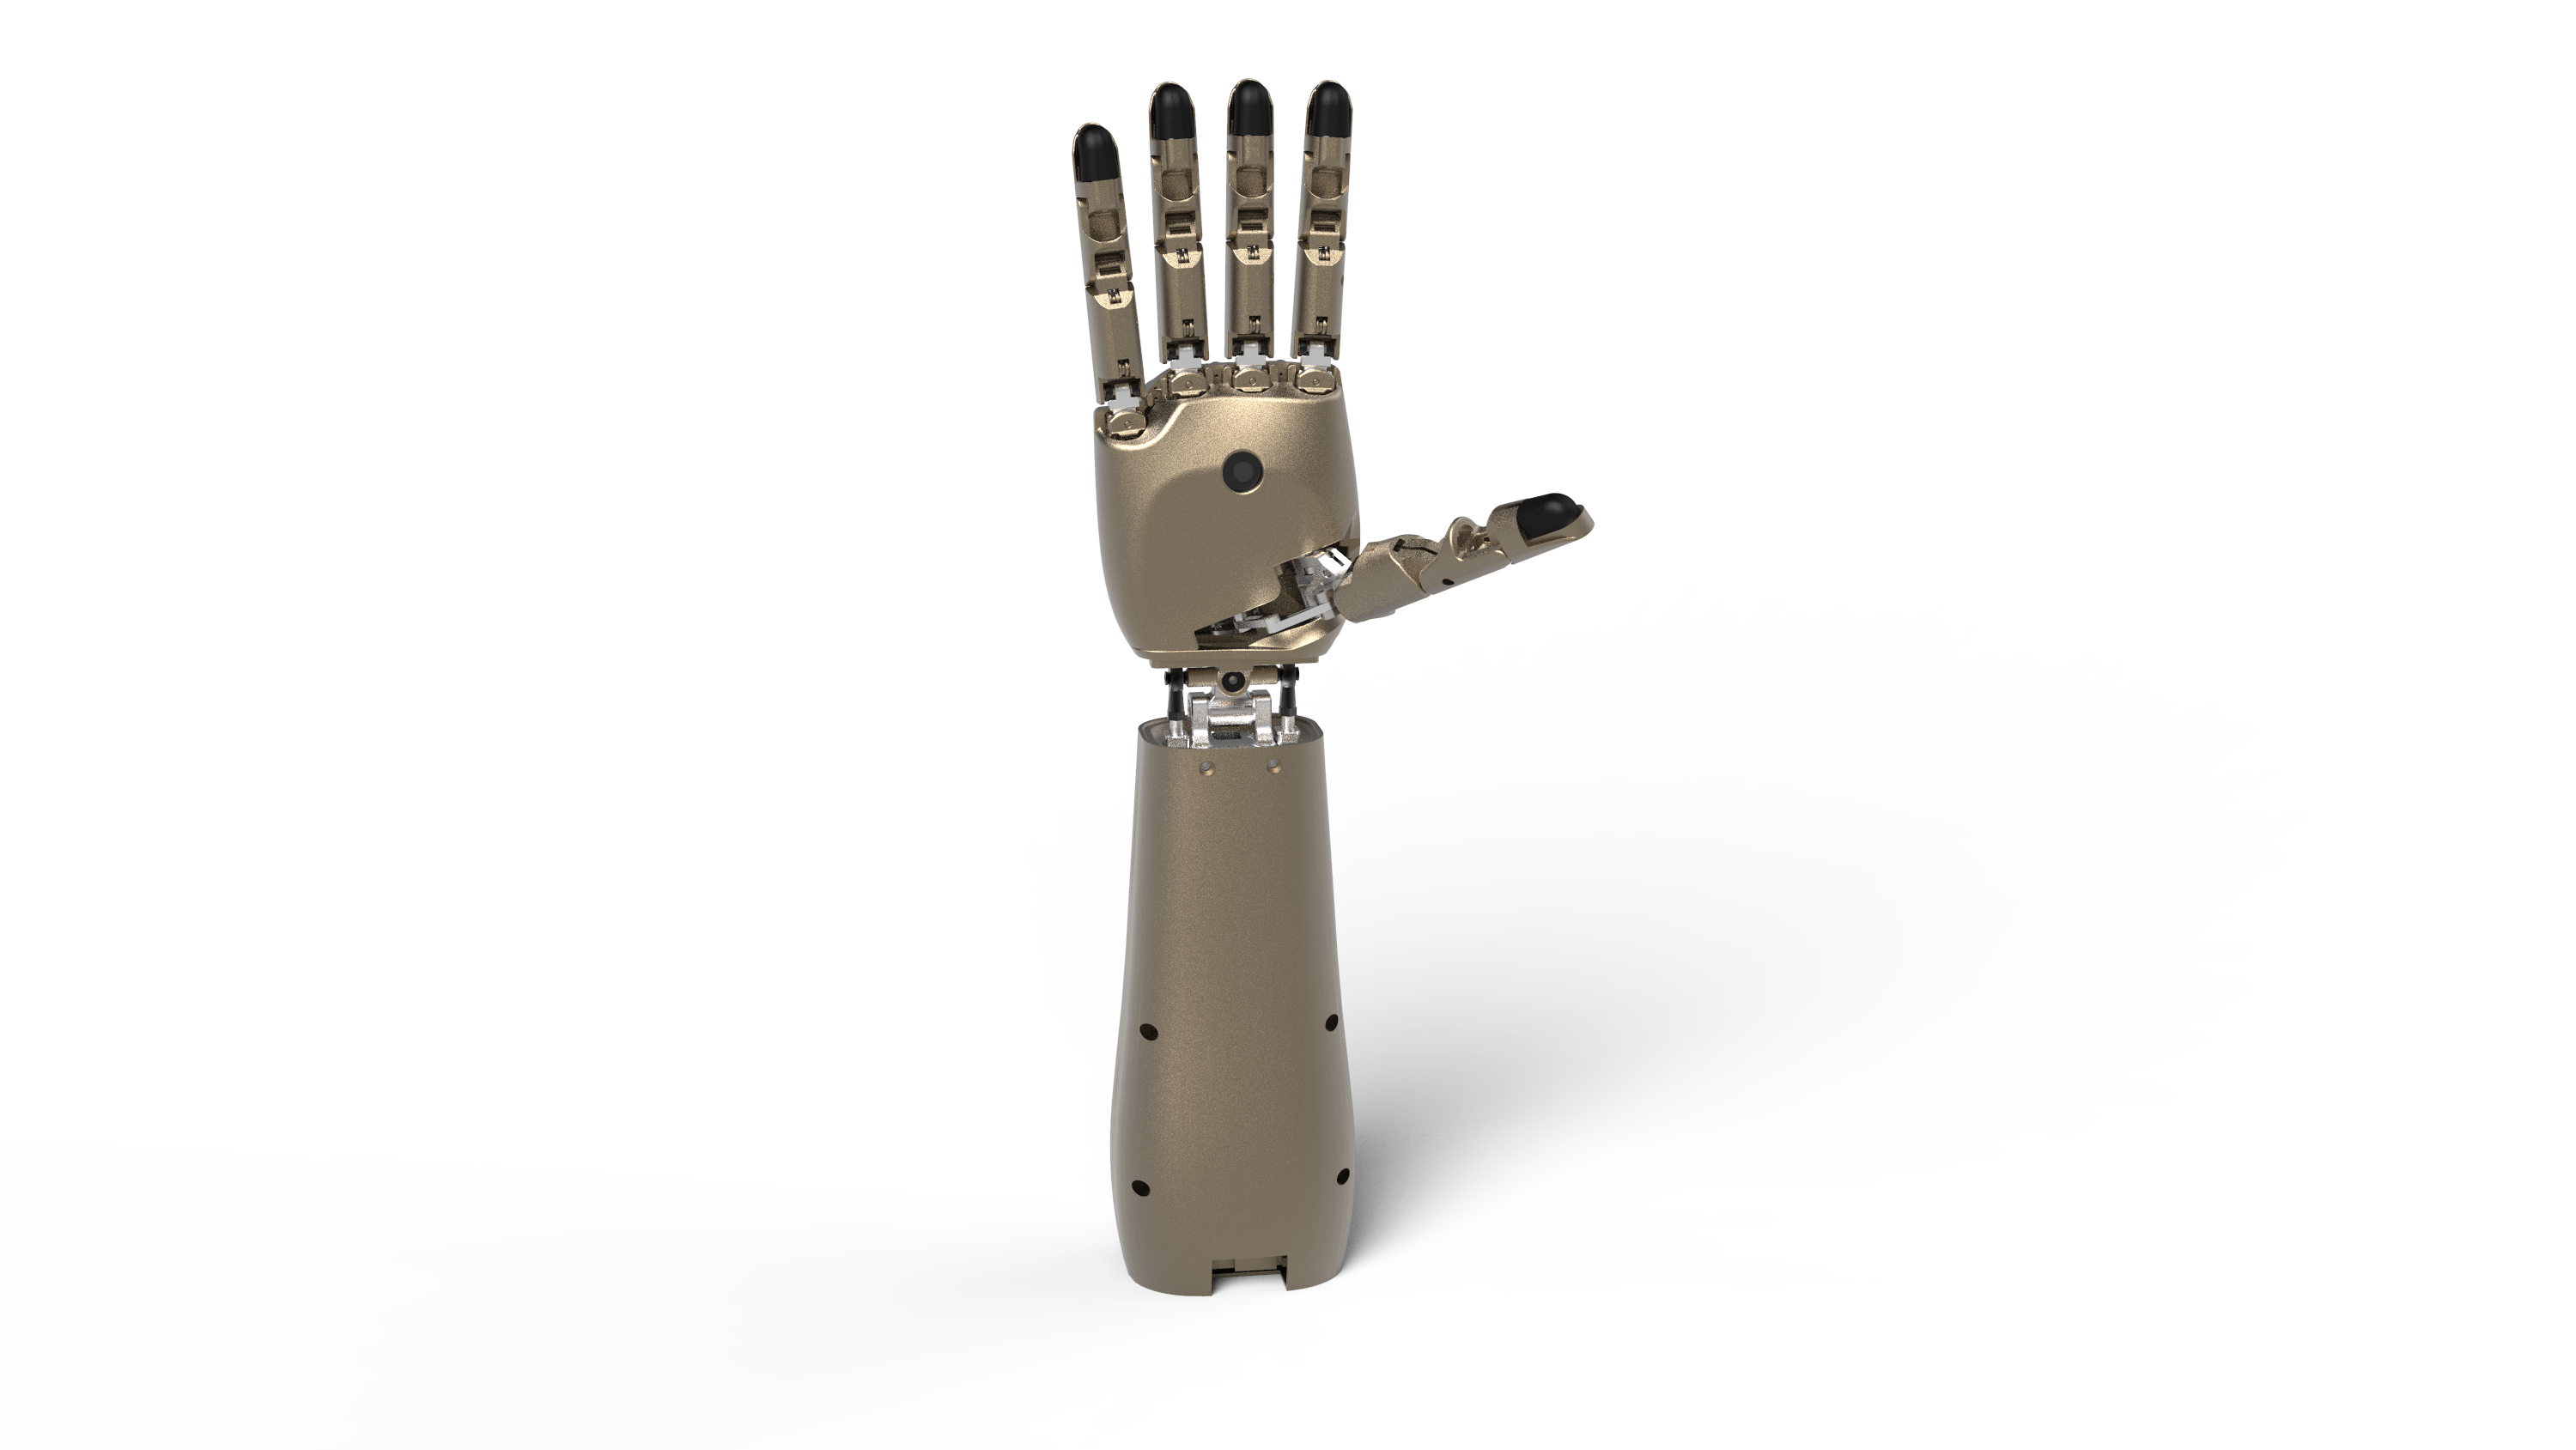
SF DEXA 02
From delicate pinching to enveloping power grasps, SF DEXA 02 brings human-inspired dexterity to robotic manipulation.
Degrees of Freedom:
22 (13 Active, including 2 wrist DOFs)
Dimension:
200 x 165 x 45 mm
Weight:
950 g
Drive Method:
Tendon + Linkage
Communication:
CAN/CANFD/ECAT
Flexion/Extension Speed:
0.6 s
Max Load:
CAN / CAN FD / RS485 / ECAT